Yiting Chen 陈一霆
I am a Computer Science Ph.D. student at Rice University, advised by Prof. Kaiyu Hang in the Robotics and Physical Interactions Lab (RobotΠ Lab).
I work on scaling robotic dexterity via structurephysics, geometry, and heuristics, baked in as inductive bias, datasimulation, web video, and the mix that scales, learningreinforcement learning and world models, evaluationsim for the sanity check; the real world decides.
Previously, I obtained a B.Eng. from Wuhan University with Prof. Miao Li and an M.Sc. from Chalmers with Prof. Yasemin Bekiroglu. I also spent time at Amazon IRG and EPFL LASA.
 ManipulationNet
Spotlight: Test Your Robot’s Skills in NIST’s Global Online Competition
My research centers on robot manipulation — specifically, enabling robots to perceive and change the configuration of the world through physical interactions under uncertainty.
- Robotic Dexterity Learning: Scalable data and policy learning frameworks that leverage human and web videos alongside simulation, with multisensory sim-to-real transfer for dexterous, forceful manipulation.
- Scalable Manipulation Benchmarking: In close collaboration with the U.S. National Institute of Standards and Technology (NIST), we measure what robots can actually do in the real world across the globe.
- Structural Priors for Manipulation: Exploiting physics, geometry, and task structure to guide robot policies, improve learning efficiency, and shape scalable manipulation data.
News
- ManipulationNet was featured in a U.S. National Institute of Standards and Technology (NIST) Spotlight.
- Joined Amazon Industrial Robotics Group in Sunnyvale, CA, as an Applied Scientist II Intern.
- Launched ManipulationNet with NIST: real-world manipulation benchmarking at scale.
- Three papers accepted to IROS 2025.
- Our work on peg-in-hole assembly accepted to RSS 2025.
- RNDF accepted to ICRA 2025.
- I joined Rice CS as a Ph.D. student in Robotics.
Publications
See also my Google Scholar.
-
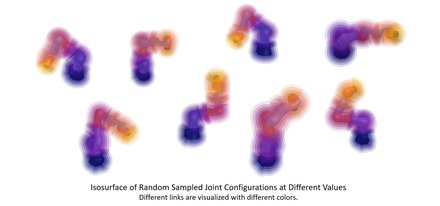
ARC-Calib: Autonomous Markerless Camera-to-Robot Calibration via Exploratory Robot Motions
IROS 2025 · Hangzhou, China
-
rt-RISeg: Real-Time Model-Free Robot Interactive Segmentation for Active Instance-Level Object Understanding
IROS 2025 · Hangzhou, China
-
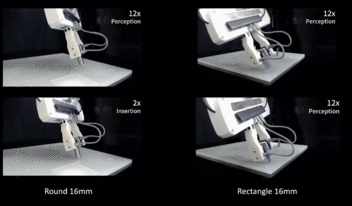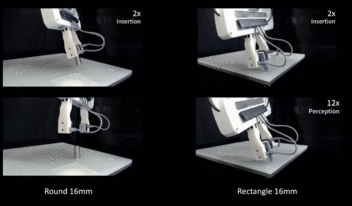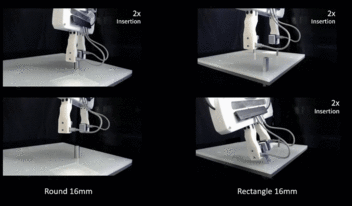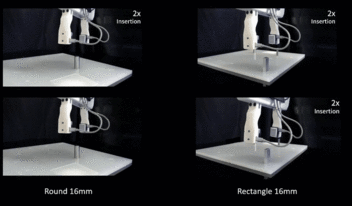
Robust Peg-in-Hole Assembly under Uncertainties via Compliant and Interactive Contact-Rich Manipulation
RSS 2025 · Los Angeles, USA
-
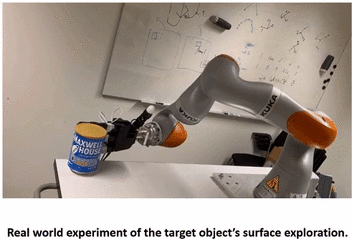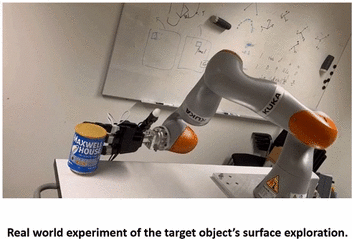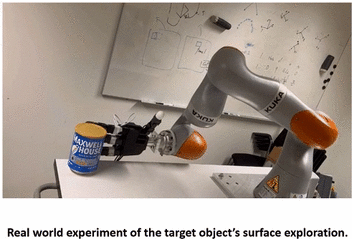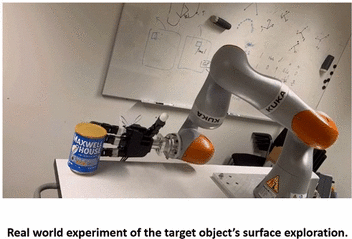
Sliding Touch-Based Exploration for Modeling Unknown Object Shape with Multi-Fingered Hands
IROS 2023 · Detroit, USA
Experience
-
Amazon Industrial Robotics Group (IRG) Applied Scientist II Intern · Sunnyvale, CA Mentors: Dr. Xin Alice Wu, Prof. Nima Fazeli, Prof. Roberto Martín-Martín
-
EPFL, Learning Algorithms and Systems Laboratory (LASA) Research Intern · Lausanne, Switzerland Advised by Prof. Aude Billard
Selected Honors & Awards
-
IEEE Robotics and Automation Society (RAS) Travel Grant ICRA 2025
-
Geyer-Vardi Scholar Department of Computer Science, Rice University $6,000 departmental fellowship
-
EPFL Excellence in Engineering (E3) Fellowship École Polytechnique Fédérale de Lausanne (EPFL) Funded summer research fellowship, <3% acceptance rate
-
Avancez Scholarship Chalmers University of Technology 75% tuition scholarship → 85% in Year 2 for academic excellence
-
Ranked 4th in Simulation Branch ICRA 2022: Open Cloud Robot Table Organization Challenge (OCRTOC)
-
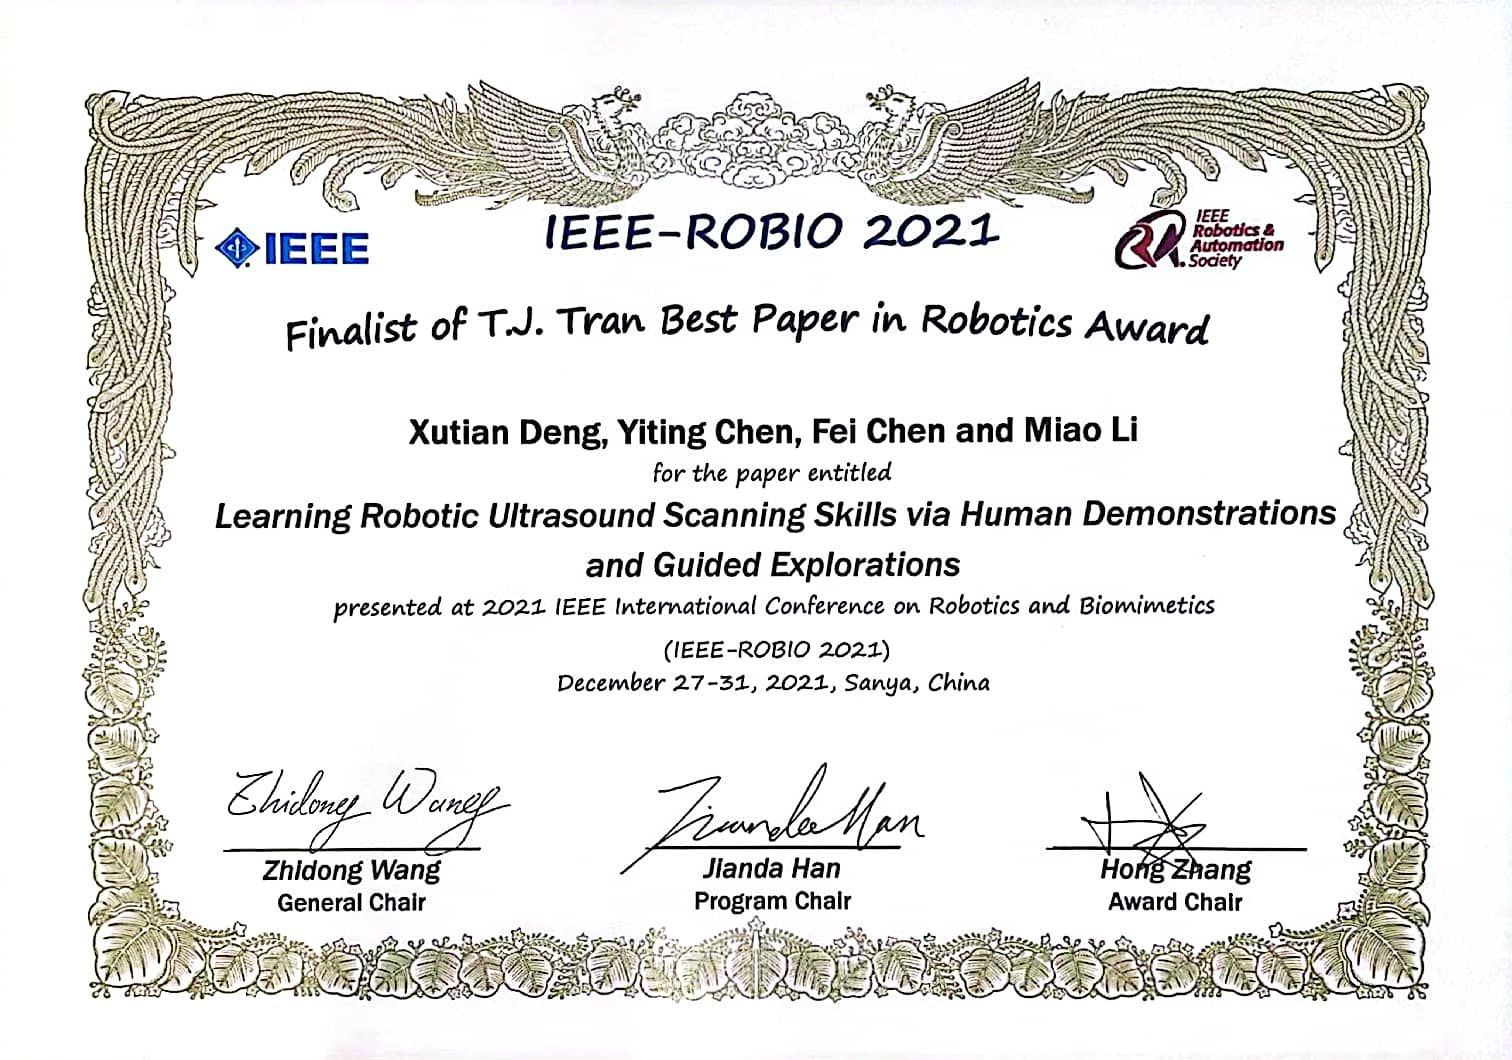
T.J. Tarn Best Paper in Robotics Award, Finalist IEEE International Conference on Robotics and Biomimetics (ROBIO)
-
Real Robot Stage Finalist IROS 2020: Open Cloud Robot Table Organization Challenge (OCRTOC)
Service
I serve as the Technical Chair of ManipulationNet.
I serve as a reviewer for: IJRR, TOG, RA-L, SIGGRAPH Asia, CoRL, T-Mech, ICRA, IROS, CASE, UR.
I served as a TA for COMP 462/562: Introduction to Modern Robotics (Spring 2025, Spring 2026) and COMP 341: Practical Machine Learning (Fall 2025).